Start with the aircraft.
Plan power, mounting and GPS data paths around your PX4 flight controller.
PX4 RTK documentation ↗RTK NAVIGATION / A NEW APPROACH
A compact RTK + 4G concept designed to bring network corrections closer to your aircraft.
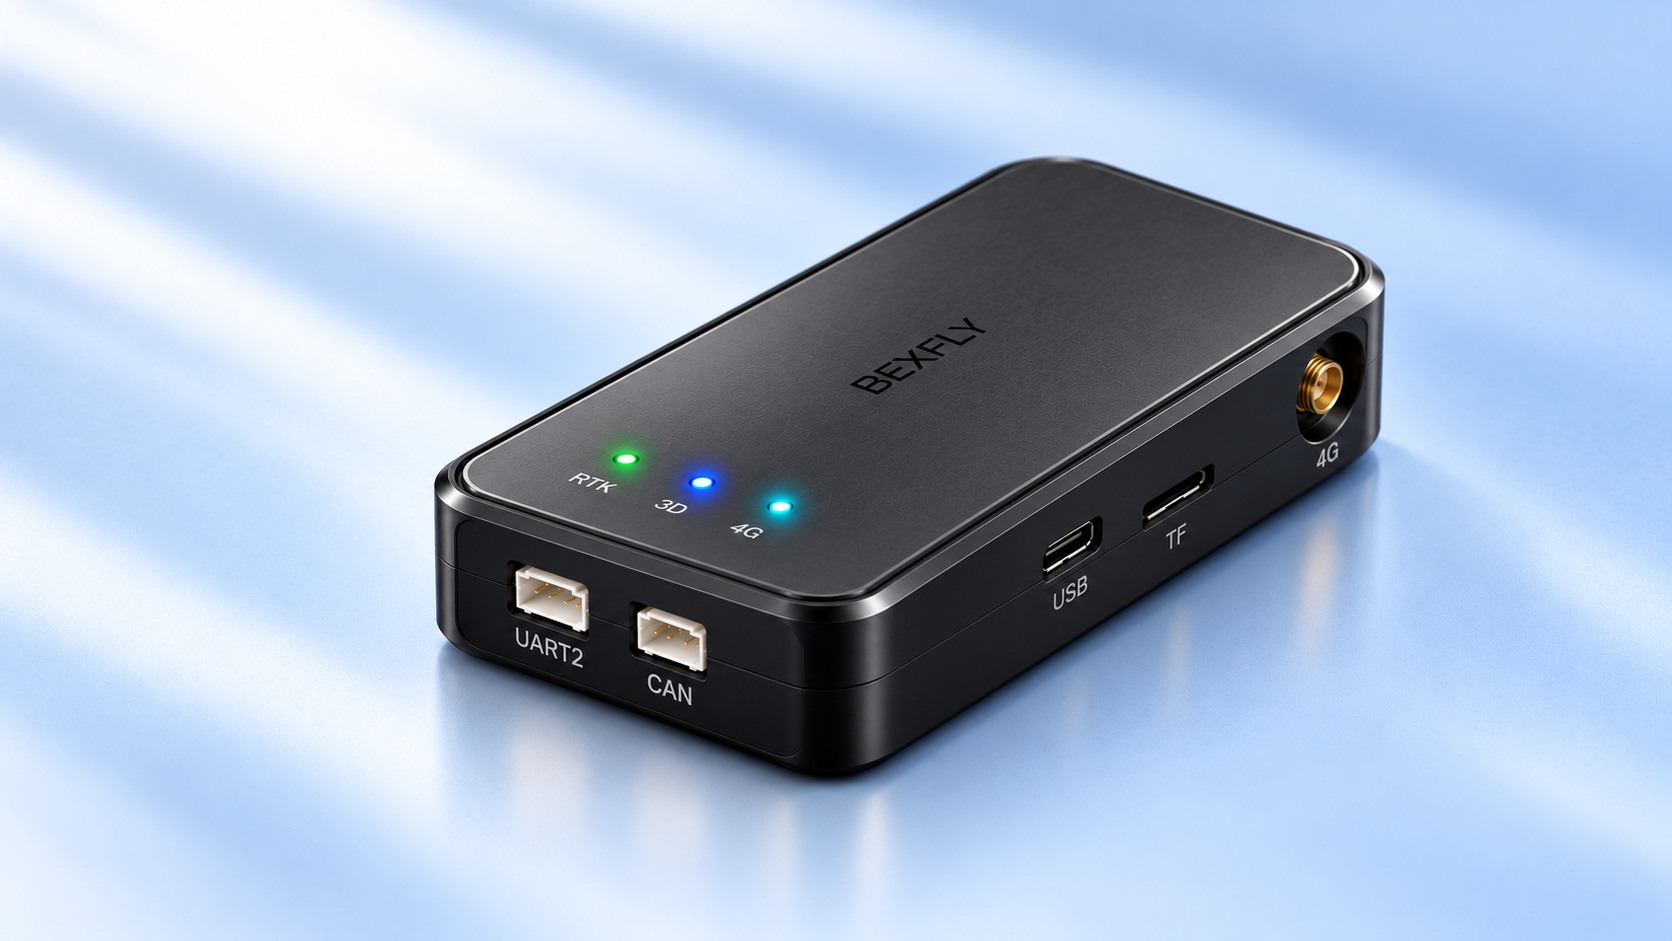 BEXFLY / RTK + 4G CONCEPTAI-generated industrial design concept. Not production photography.
FLIGHT CONTROL & NAVIGATION
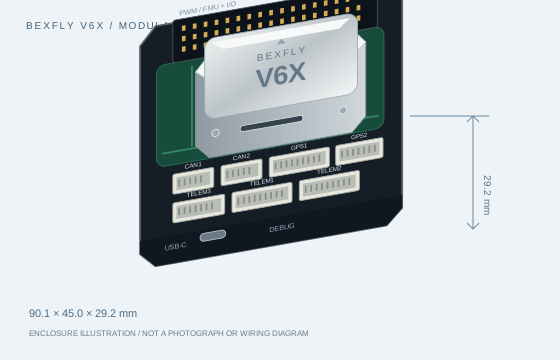
The BEXFLY V6X flight controller brings the aircraft, navigation and peripheral interfaces into one integration plan.
Standard GNSS positioning based on the u-blox M10 platform. A focused navigation option for aircraft that do not require RTK corrections.
High-precision GNSS positioning based on the u-blox F9P platform, with RTK processing in the receiver and a correction stream for precise positioning.
FEWER THINGS BETWEEN YOU AND FLIGHT
The proposed architecture brings cellular correction access and RTK processing into one module, reducing the need for a separate local base station in supported deployments.
Inside the architecture ↗OPEN FLIGHT, THOUGHTFULLY CONNECTED
Plan power, mounting and GPS data paths around your PX4 flight controller.
PX4 RTK documentation ↗Review GPS configuration and CAN requirements for your ArduPilot installation.
ArduPilot RTK documentation ↗Connector shape alone does not establish compatibility. Confirm pinout, firmware and wiring before connection.
Read the integration checklist ↗PX4, ArduPilot and Pixhawk are third-party ecosystem references. Compatibility is a development target, not a certification or partnership claim.
BUILD YOUR NEXT FLIGHT
Prepare your platform requirements and start with the right integration questions.
Prepare a project inquiry ↗